
Projects
A complete archive of 59 New Dexterity research projects spanning robotic hands, grippers, aerial robots, prosthetics, muscle-machine interfaces, teleoperation, and benchmarks.
Robot Hands & Grippers (16)
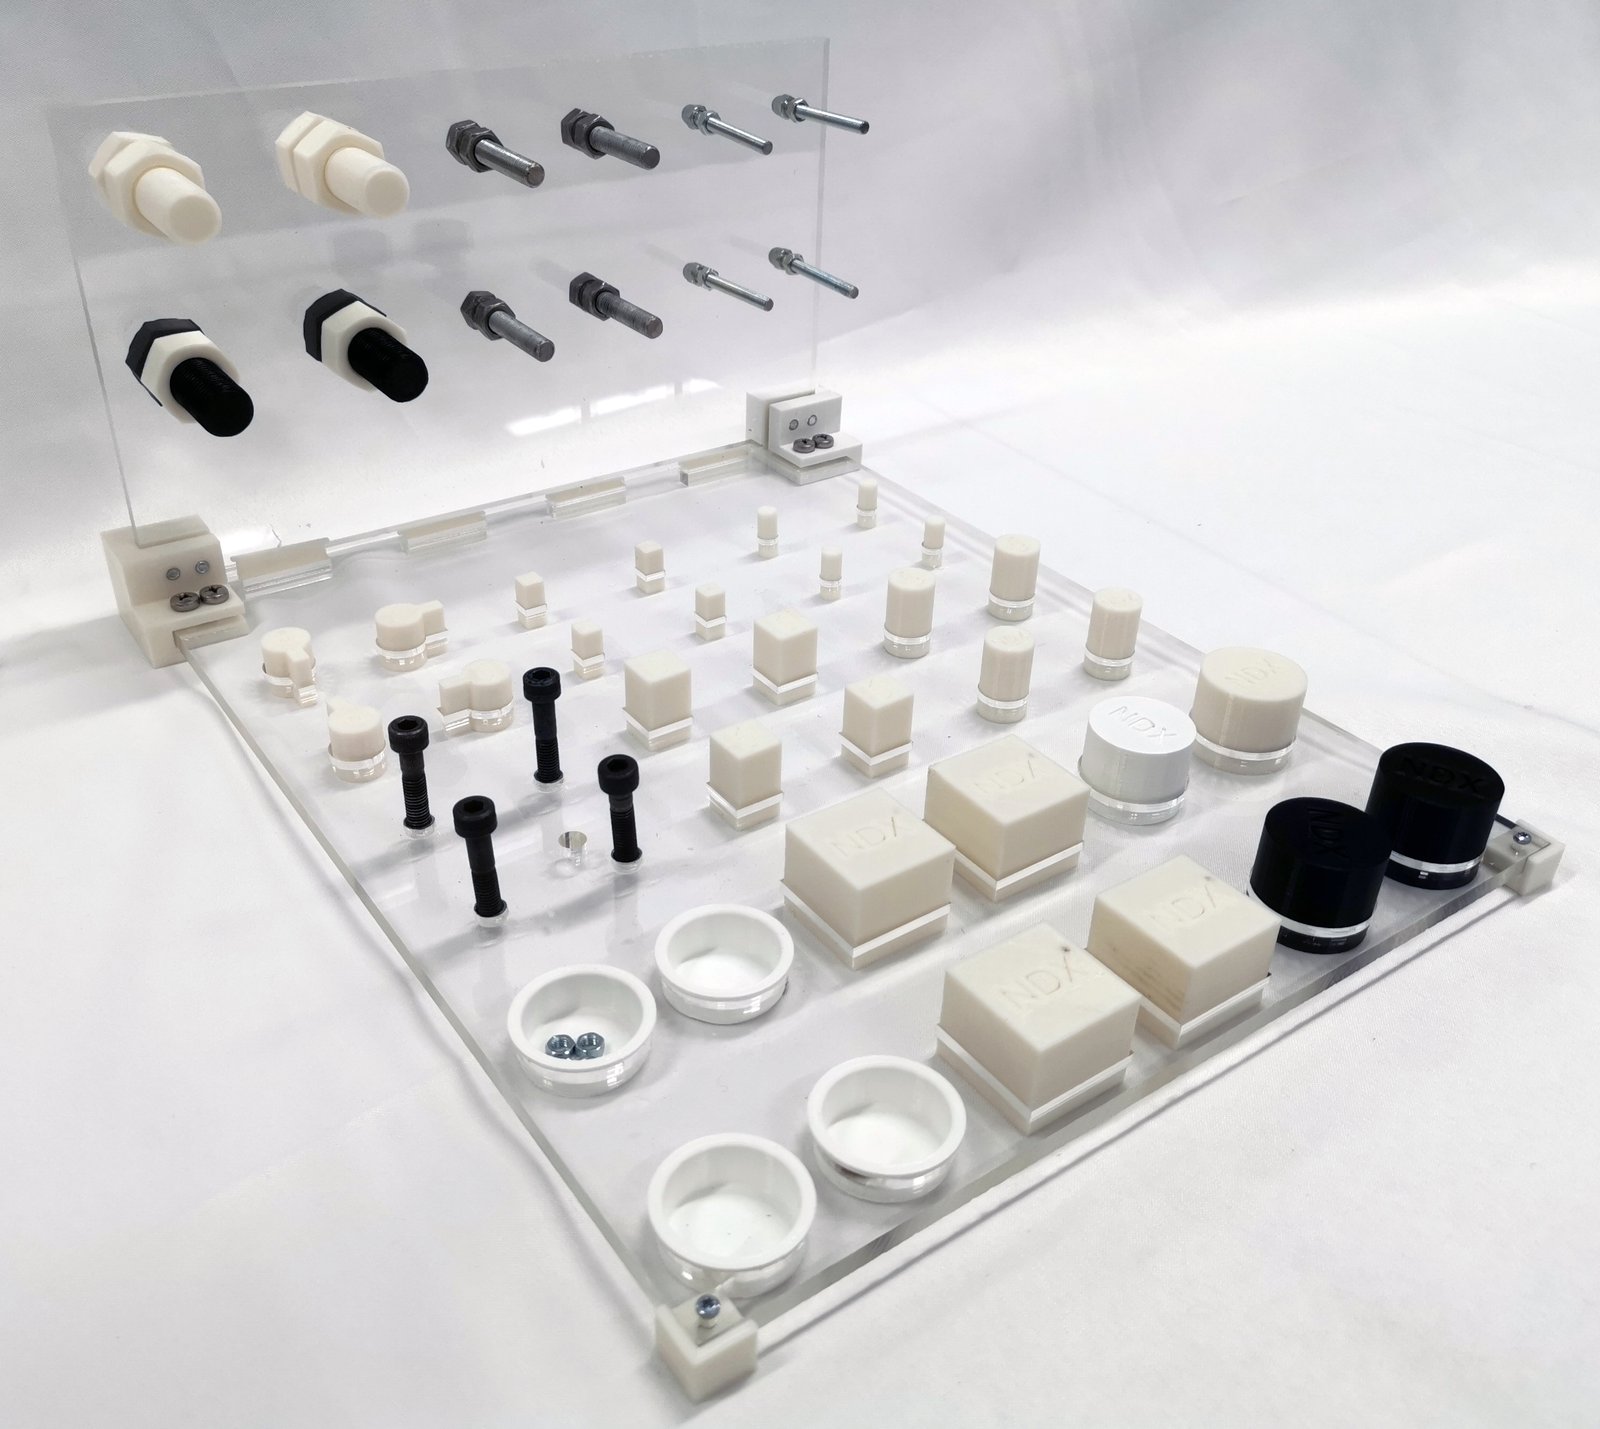
Dexterity Test
Description Despite the plethora of studies focusing on the design and development of dexterous robotic grippers and hands, researchers have not been able to quantify dexterity due to the lack of well defined measures or tests. Human dexterity on the other han…
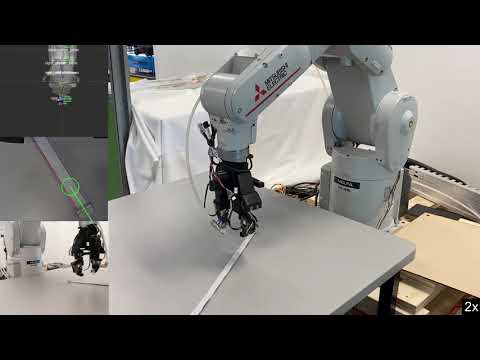
Cable Gripper
Flexible flat cables (FFC) are very popular for connecting different components in modern electronics (e.g., mobile phones, laptops, tablets, etc.). The manipulation of FFCs typically relies on highly trained workers that spend hours performing the same repeti…

Soft, Disposal Robotic Gripper

Series Elastic, Compact Differential
Differential mechanisms allow the designers of robotic and prosthetic grippers and hands to create devices that require a minimal number of motors in order to grasp a plethora of everyday life objects, leading to light-weight, compact, and low-cost implementat…
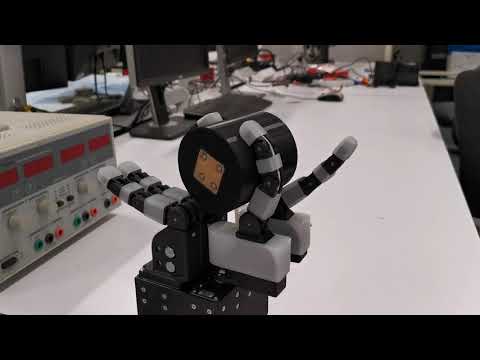
The New Dexterity Multi-Grasp, Hybrid Hand
Robot grasping and dexterous, in-hand manipulation allow robots to interact with their surroundings and execute a plethora of complex tasks such as pushing buttons, opening doors, and interacting with electrical appliances. In robotics, such complicated tasks …

Multi-Modal Gripper
This work proposes a framework that improves the dexterous manipulation capabilities of two fingered grippers by optimizing the finger link dimensions and analyzing the effect of finger symmetry and the distance between the finger base frames on their manipula…

Multi Modal Cable Gripper
On Robotic Manipulation of Flexible Flat Cables: Employing a Multi-Modal Gripper with Dexterous Tips, Active Nails, and a Reconfigurable Suction Cup Module

Kirigami Based Grippers
Over the last decade a plethora of soft robotic devices has been proposed for the execution of complex grasping and dexterous manipulation tasks. Tasks that require such an increased dexterity are typically executed using fully-actuated, rigid end-effectors th…

humanmachineinterfaces
On Wearable, Lightweight, Low-Cost Human Machine Interfaces for the Intuitive Collection of Robot Grasping and Manipulation Data

meshjamming
Soft robots are capable of effortlessly adapting to their environment using elastic materials that impart structural compliance into their designs, allowing them to execute complex tasks with minimal sensing and control. However, soft robots cannot exert high …

tatum
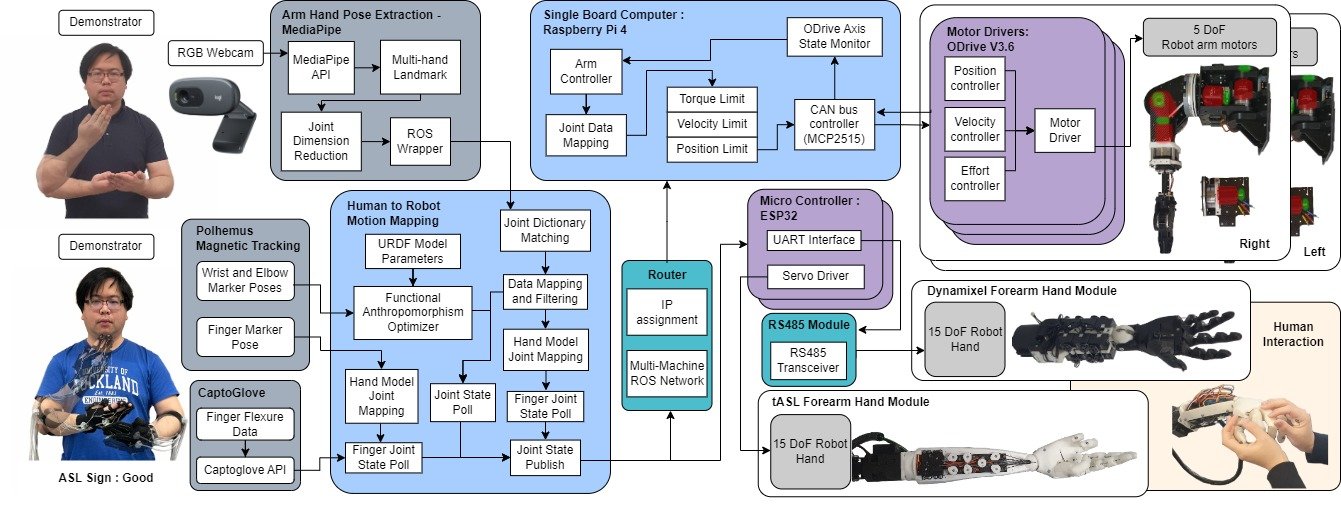
To communicate, the ∼1.5 million Americans living with deafblindess use tactile American Sign Language (t-ASL). To provide DeafBlind (DB) individuals with a means of using their primary communication language without the use of an interpreter, we developed an …

NDX-A: The New Dexterity Adaptive, Humanlike Robot Hand

compactkirigamigrippers
Over the last decade a plethora of soft robotic devices has been proposed for the execution of complex grasping and dexterous manipulation tasks. Tasks that require such an increased dexterity are typically executed using fully-actuated, rigid end-effectors th…

kirigamiobjectdetection
Soft robotic devices have been popular in handling intricate grasping and dexterous manipulation tasks, serving as an alternative to conventional, rigid end-effectors. These devices are relatively simple, lightweight, and cost-effective. Recently, kirigami bas…
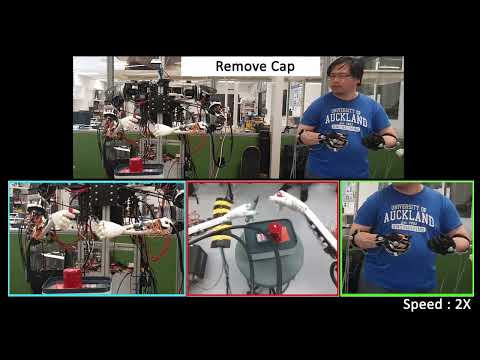
OpenBMP
This work introduces the New Dexterity modular, dexterous, open-source, anthropomorphic bimanual manipulation system that is designed for research and rapid experimentation in robot grasping, dexterous manipulation, and bimanual manipulation. The platform comb…
tASL
An estimated 0.2% of the world population is living with severe deafblindness, with approximately 1.5 million Americans using tactile American Sign Language (t-ASL) as their primary form of communication. To allow them to communicate without an in-person inter…
Aerial Robots & UAVs (15)
OmniRotor
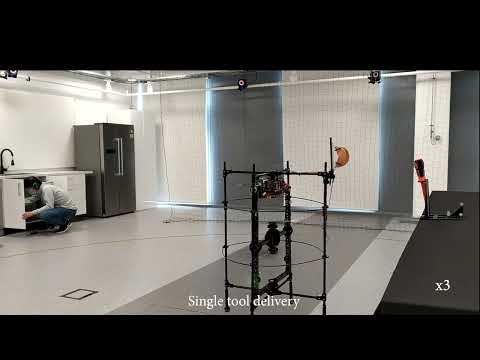
Aerial grasping has many applications in the fields of search-and-rescue, maintenance, inspection, and the delivery industry. However, there are still many limitations to be overcome, including better and more lightweight gripper solutions, and more efficient …

Airship Shared Control
Small, lighter-than-air (LTA) robotic airship platforms offer an alternative to the more common, rotor-based Unmanned Aerial Vehicles (UAVs). LTA vehicles are attractive due to their inherent safety, mobility, low power consumption, and extended flight times, …
Coaxial Rotors Benchmarking Platform
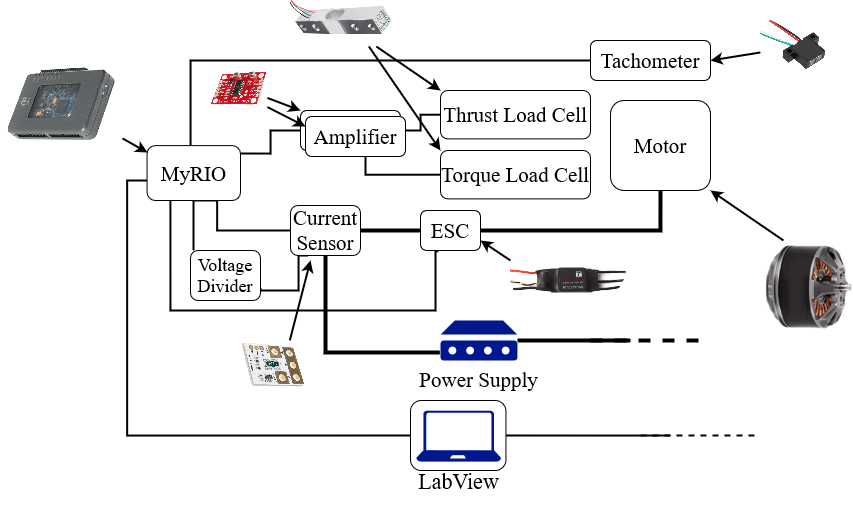
Abstract: Coaxial rotors of the type used primarily on multi-rotor Micro Aerial Vehicles (MAVs) are complex aerodynamic systems. Since aerodynamics is not the focus of the robotics community, there is not much research available investigating them. In this wor…
ARoA
The ongoing global healthcare crisis has amplified the need for automation of manual tasks in several industries and service sectors. Simple household tasks such as tidying and cleaning are in high demand, with only a few robotic platforms capable of performin…

reconfigurabledrones
Unmanned Aerial Vehicles (UAVs) are quickly becoming the future of payload delivery. Over the past few years, many designs have surfaced with a variety of different solutions to this problem. Current systems are often bulky and designed for a specific purpose.…
CASE2022
In the UAV field, the efforts to develop drones with more payload and flight time capacity are constant. Coaxial multirotor drones offer high payload capacity in a relatively small vehicle footprint [1]. However, compared to regular 'flat' multi-rotors, they e…

Aerial Grasping System
The development of aerial vehicles for package delivery and transportation of arbitrary payloads is of great interest for both industry and research. However, current solutions for Unmanned Aerial Vehicle (UAV) based transportation of large objects and/or parc…

CADRL
Model Free Reinforcement Learning (MFRL) has shown significant promise for learning dexterous robotic manipulation tasks, at least in simulation. However, the high number of samples, as well as the long training times, prevent MFRL from scaling to complex real…

BioinspiredWing
Unmanned aerial vehicles (UAVs) have revolutionised various industries, such as agriculture, remote sensing, and infrastructure inspection. To explore new designs and improve UAV flight performance, roboticists are seeking inspiration from nature. In this pape…

openreconfigurabledrones
Unmanned Aerial Vehicles (UAVs) are rapidly emerging as the next-generation solution for delivering payloads. In recent years, numerous designs have been proposed, each offering distinct approaches to this challenge. Presently, existing systems tend to be cumb…
MPCvisualservoing
Over the last decades a lot of research effort has been put into the development of new Unmanned Aerial Vehicles (UAVs) and mobile robots for the inspection of critical infrastructure, such as bridges, roads, and dams, in remote locations or dangerous conditio…

OmniRotorManipulation
Aerial grasping has many applications in the fields of search-and-rescue, maintenance, inspection, and the delivery industry. However, there are still many limitations to be overcome, including better and more lightweight gripper solutions, and more efficient …

cbf_uav
Unmanned Aerial Vehicles (UAVs) can offer a versatile solution for the autonomous inspection of a variety of buildings, monuments, or infrastructure. Such inspections may take place regularly or after a sudden event (e.g., earthquake) to understand the state o…

AeroBuoy
Monitoring of waterways such as remote and hazardous rivers and streams is important so as to assess the impact of external factors including construction runoff or climate change. Versatile, autonomous robotic boats can offer excellent environmental inspectio…
UAVDLInspectionInfrastructure
Modern technologies such as Unmanned Aerial Vehicle (UAV)-based inspection and deep learning (DL) algorithms introduce new opportunities and challenges in Civil Engineering. To better facilitate the adoption and advancement of UAV-based detection technologies,…
Marine Robots (2)
AutoBoat
Autonomous boats can have a plethora of applications related to sea life and pollution monitoring, search and rescue, border patrol, inspection of internal waterways and the open ocean, among others. Moreover, the design, development, and control of such platf…

trimaran
Versatile, autonomous robotic boats can offer excellent environmental inspection and monitoring solutions for remote, dangerous, hard to reach, or access protected water bodies. This paper introduces such a platform in the form of an autonomous, cost-effective…
Prosthetic Hands (4)

Lockable Prosthesis
Over the last decade, adaptive tendon driven devices have gained an increased interest from the research community for their lightweight, compact, and affordable design features attributed to the utilisation of underactuation, differential mechanisms, and stru…

Hyperadaptive Prosthesis
Children with congenital limb loss undergo a different prosthetic journey than adults who have suffered from traumatic limb loss. As the children are born without a limb, the use of a prosthesis can feel foreign, creating discomfort. This results in higher mea…

OpenBionicsProsthesis
In this work, we present a 16 degree of freedom (DoF) underactuated robotic hand specifically designed to achieve increased dexterity and the execution of dexterous manipulation tasks with minimal cost. Three Dynamixel XM430-W350-R actuate the hand via a combi…

Prosthetic Training
This work presents an adaptive prosthetic training gripper with a compact, variable stiffness differential mechanism and a vision-based based shared control scheme that relies on a Lightmyography (LMG) interface to trigger the selected grasps. The gripper inco…
Wearable Robotics & Exogloves (1)

Muscle Machine Interfaces (10)

Forcemyography Interface
With an increasing number of robotic and prosthetic devices, there is a need for intuitive interfaces which enable the user to efficiently interact with them. The conventional interfaces are generally bulky and unsuitable for dynamic and unstructured environme…

EMG Shared Control
Over the years, robots have seen an increased use in a wide range of applications including exploration, maintenance, and search and rescue operations in remote or hazardous environments. Developing fully autonomous systems for unstructured environments is a c…

Feature Extraction
With an increasing number of robotic and prosthetic devices, there is a need for intuitive Muscle-Machine Interfaces (MuMIs) that allow the user to have an embodied interaction with the devices they are controlling. Such MuMIs can be developed using machine le…

EMG Based Robotic Telemanipulation
Electromyography (EMG) signals are commonly used for the development of Muscle Machine Interfaces. EMG based solutions provide intuitive and often hand-free control in a wide range of applications that range from decoding of human intention in classification t…

LMGTclassification
The increasing use of smart technical devices in our everyday lives has necessitated the use of muscle-machine interfaces (MuMI) that are intuitive and that can facilitate immersive interactions with these devices. The most common method to develop MuMIs is us…

EMGpotentialfields
Telemanipulation is widely used in robotics applications, ranging from maintenance of various industrial systems to search and rescue response in remote and/or hazardous environments. Human operators are often responsible for the control of such robotic system…

EMGaffordances
Over the last decades, significant research effort has been put into creating Electromyography (EMG) based controllers for intuitive, hands-free control of robotic arms and hands. To achieve this, machine learning models have been employed to decode human moti…

EMGPF
Numerous robotics applications have utilized telemanipulation frameworks to perform tasks in remote or dangerous environments. During execution of telemanipulation tasks using robotic systems, human operators are in charge of controlling these systems effectiv…

LMG-SEprosthesis
In recent years, the research community has shown growing interest in adaptive, tendon-driven devices due to their lightweight, compact, and cost-effective designs. These features are made possible by utilizing underactuation, differential mechanisms, and stru…
LMGSemiautonomous
Humanlike robotic hands such as prosthetic hands become more advanced as technology develops, giving us more lightweight, sophisticated solutions with multiple degrees of freedom. Alongside the hardware improvements, control systems and human machine interface…
Teleoperation & Skill Transfer (3)

Enhanced Virtual Reality Based Robotic Teleoperation
Over the last decade, many studies have focused on Virtual Reality (VR) frameworks for remotely controlling robotic systems. Although VR systems have been used to teleoperate robots in simple scenarios, their effectiveness in terms of accuracy, speed, and usab…

Teaching Interface
Modern collaborative and industrial robots are typically accompanied by proprietary control interfaces, which may also offer basic teaching functionality. However, many such interfaces are not suited for frequent reconfiguration of the robot system, which is e…

scalableskilltransfer
Humans are capable of performing intricate and complex tasks, enabling seamless interaction with their surroundings. Therefore, capturing the human demonstrated skills and transferring these skills to robots is beneficial when engaging with and executing tasks…
Datasets, Benchmarks & Competitions (8)

New Dexterity - Robotic Grasping and Manipulation Competition (MECHENG 736/730)
Lecturers of Engineering courses around the world are struggling to increase the engagement of students through the introduction of appropriate hands-on activities and assignments. In Biomechatronics and Robotics courses these assignments typically focus on ho…
WRO
World Robot Olympiad New Zealand Finals Thursday-Friday, 6-7 October 2022, 5:00 pm - 8:00 pm 5 Grafton Rd, Auckland 1010 Rooms: 405-352, 405-389, 405-488 Season Theme: My Robot My Friend The New Zealand Final will only host the following categories: Future Inn…
IROS Robotic Grasping and Manipulation Competition
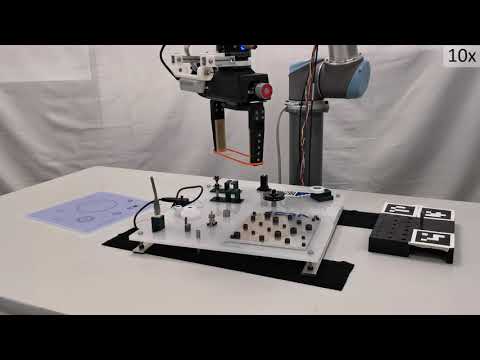
As manufacturing trends shift towards customized production, the demand for agile automation systems capable of efficient adaptation to rapidly changing task requirements is rising. This work presents a flexible robotic assembly system that combines CAD based …

kitchendataset
Over the last decades there has been a lot of research effort focusing on the development of household robots. Such robots need to execute a plethora of complex tasks that require significant dexterity and that need to be employed in dynamic and unstructured e…
Manipulation Testbed
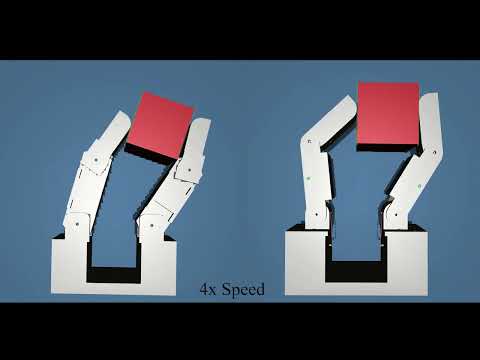
Teaching robots to manipulate objects is of critical importance as dexterous, in-hand manipulation is a necessary skill that enables them to operate and interact with a world designed for humans, executing complex tasks. This thesis focuses on the design and d…
CASE2023
IEEE International Conference on Automation Science and Engineering (CASE) is the flagship conference of the IEEE Robotics & Automation Society. It provides a primary forum for multidisciplinary research in automation. CASE'2023 will be held in Auckland, N…
Robothon
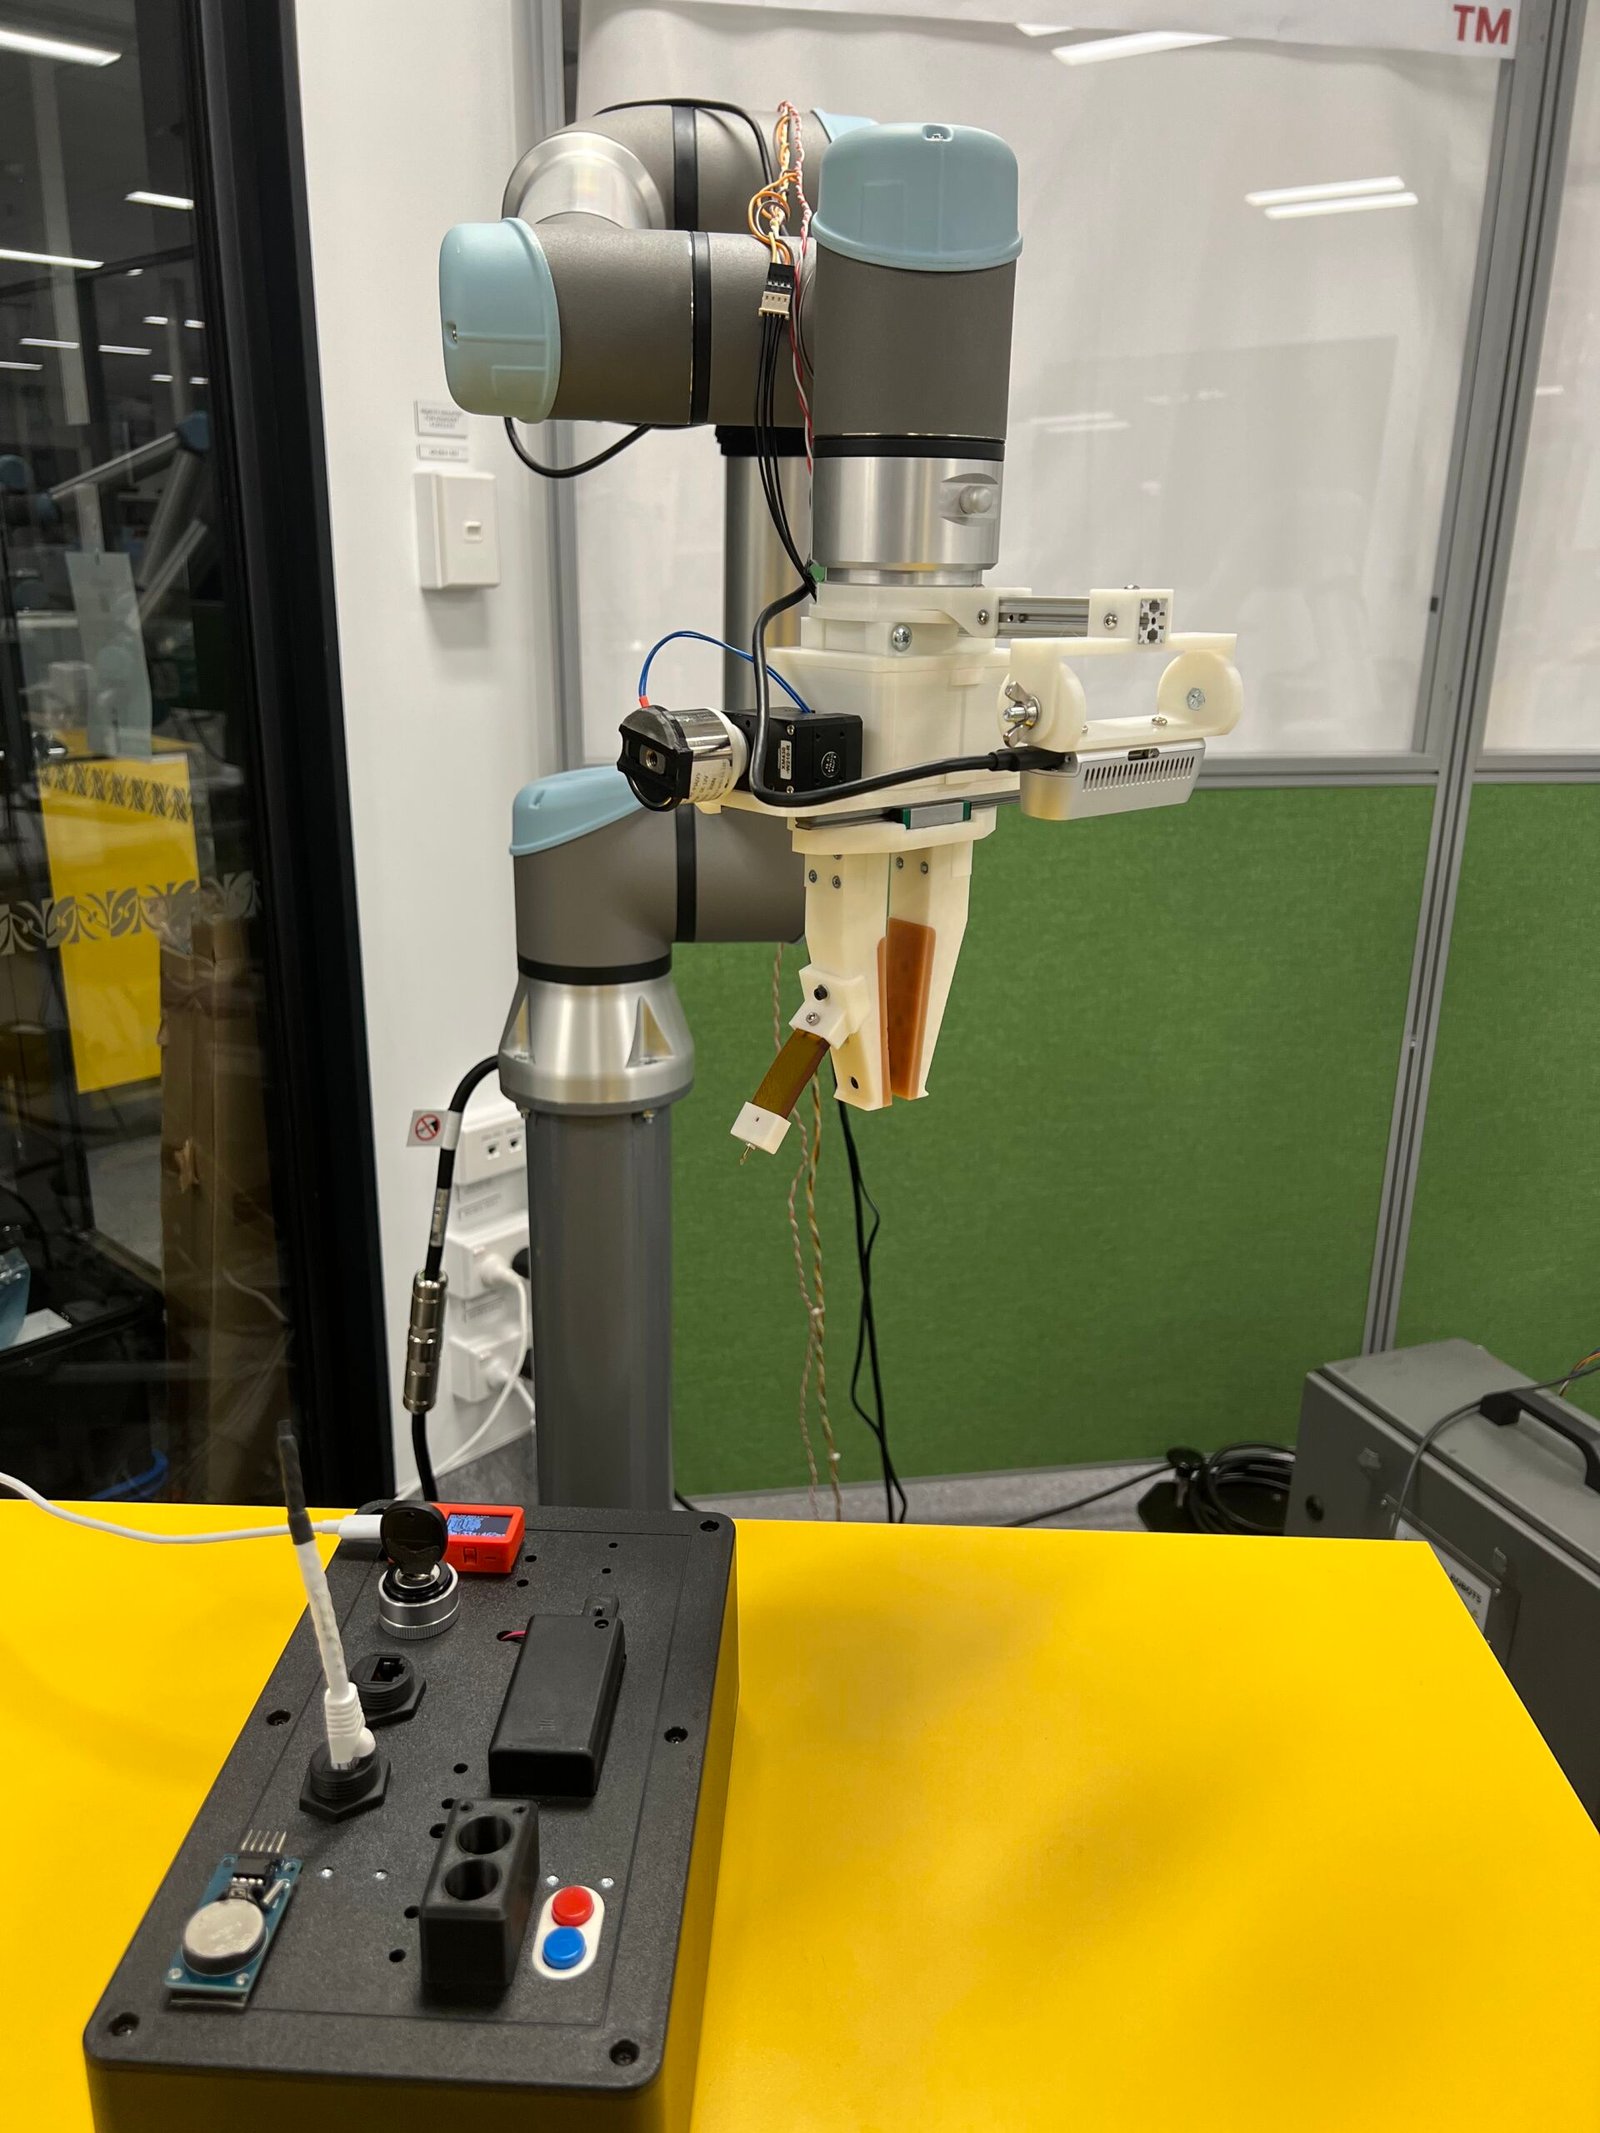
The Solution - An Adaptive Robot Arm Gripper System For the 2022 Robothon Grand Challenge the New Dexterity team uses a robot arm gripper system that consists of a Universal Robots UR5e robotic arm and a custom, adaptive parallel-jaw gripper. The gripper has b…
everydaygraspdataset
The control of high degree of freedom prosthetic hands requires high cognitive effort and has proven difficult to navigate particularly as prosthetic hands become more advanced. To reduce control complexity, vision-based shared control methods have been propos…